RobotKraft — Autonomous Robotic Arm
Overview & Objective
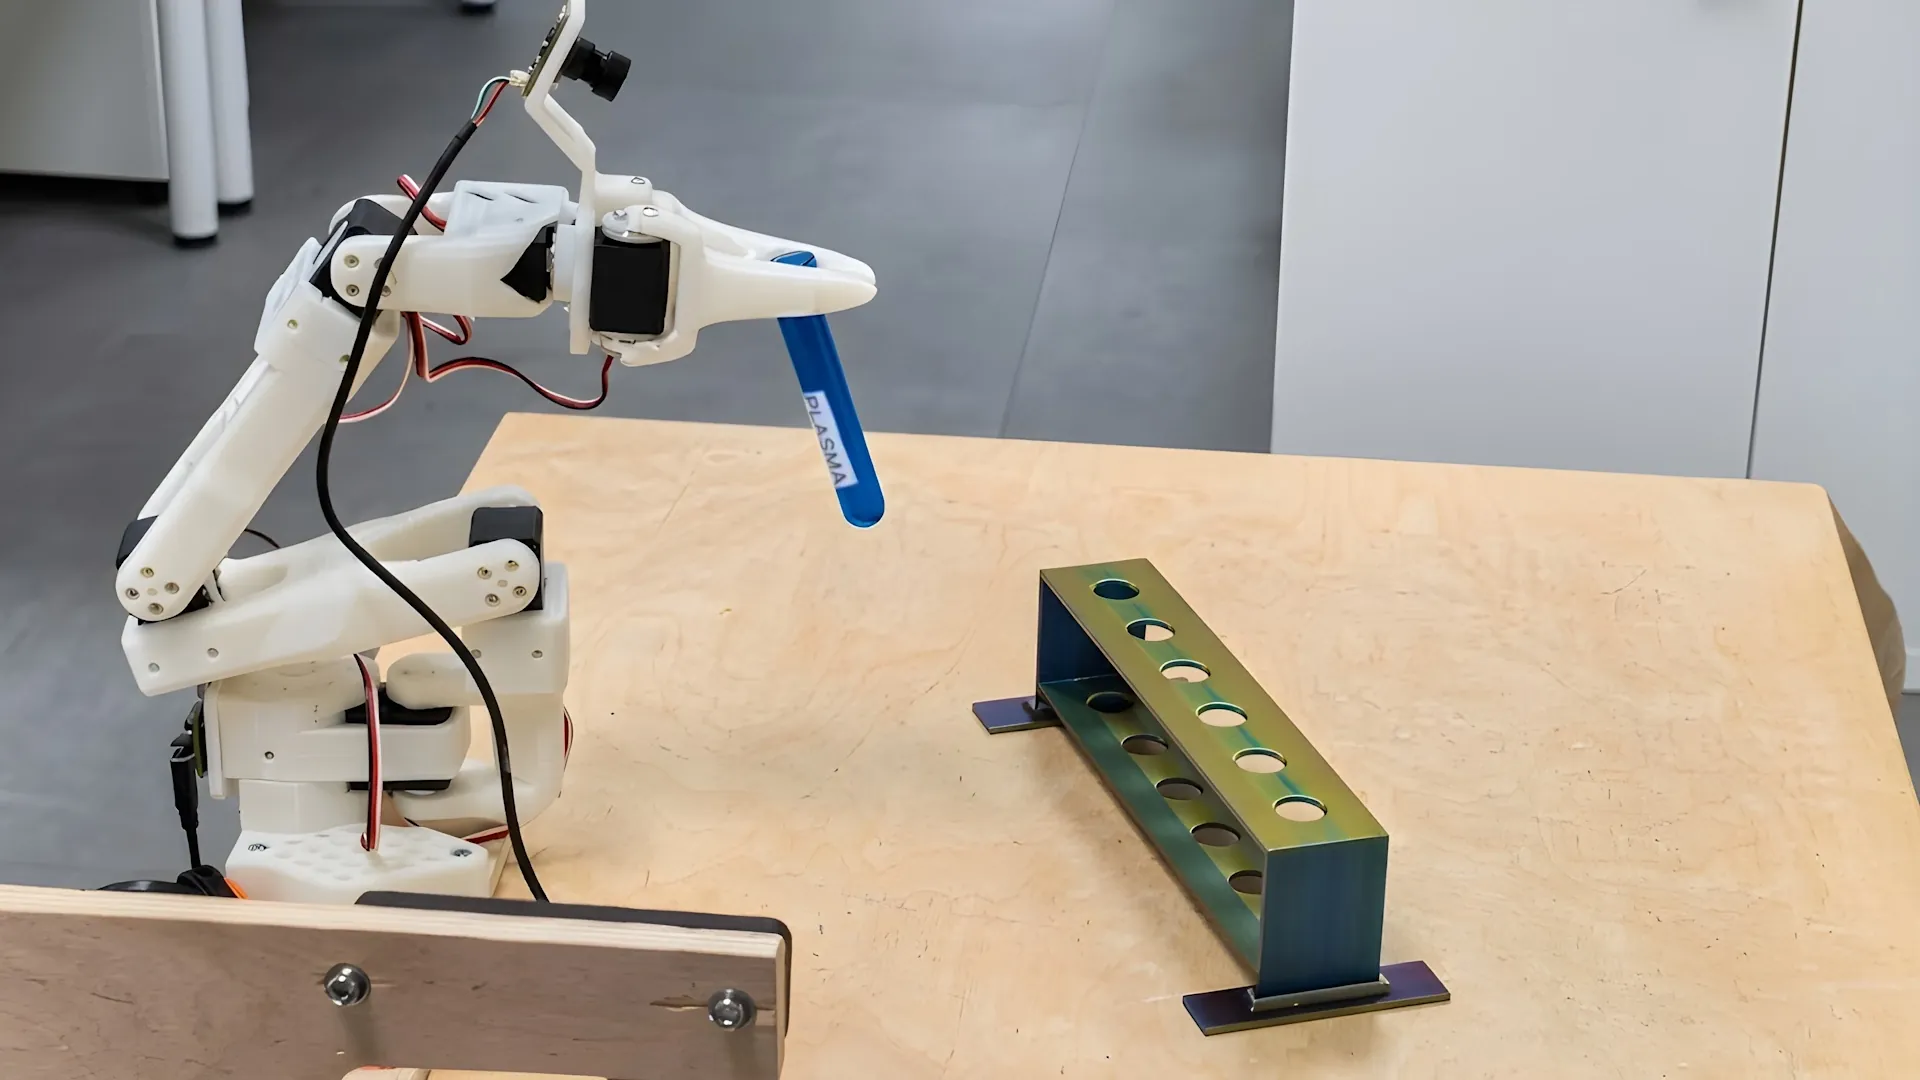
Autonomous physical robotic arm manipulation system developed during RobotKraft, an intensive 3-day AI & robotics hackathon organized by Alsace Digitale at Télécom Physique Strasbourg (InnovLab). Leveraged the Hugging Face LeRobot framework and multi-camera computer vision to train imitation learning policies on a physical SO-ARM101 robot arm (leader/follower setup), addressing real-world latency, sensor noise, dual voltage buses (12V follower, 5V leader), and mechanical friction.
Technical Hardware & Docker Architecture
Robotic Arm Setup
Dual SO-ARM101 setup (leader arm for human teleoperation data recording, follower arm for policy execution).
Camera Ingestion
InnoMaker U20CAM wrist camera for gripper-level alignment and OAK-D Lite depth camera for global scene understanding.
Dockerized Microservices
Containerized LeRobot modules with CUDA GPU acceleration for local training and dialout group device passthrough.
Key Engineering Highlights
Physical AI & Policy Training (LeRobot)
Trained behavioral cloning and imitation learning policies using Hugging Face LeRobot to execute fine-grained pick-and-place tasks with the SO-ARM101 arm.
Multi-Camera Vision Pipeline
Integrated multi-angle camera streams (InnoMaker U20CAM wrist camera and OAK-D Lite depth scene camera) for real-time spatial perception and workpiece localization.
Docker Containerized Infrastructure
Containerized teleoperation, dataset recording, and model training services (lerobot-follower, lerobot-leader, lerobot-camera, lerobot-gpu) with persistent udev hardware symlinks.
Sim-to-Real Hardware Kinematics
Interfaced high-level policy inference with low-level servo motor controllers, actively compensating for mechanical play, latency, and sensor noise.