Axiom Chess: Spatial Computing & HCI Ecosystem
Overview & Objective
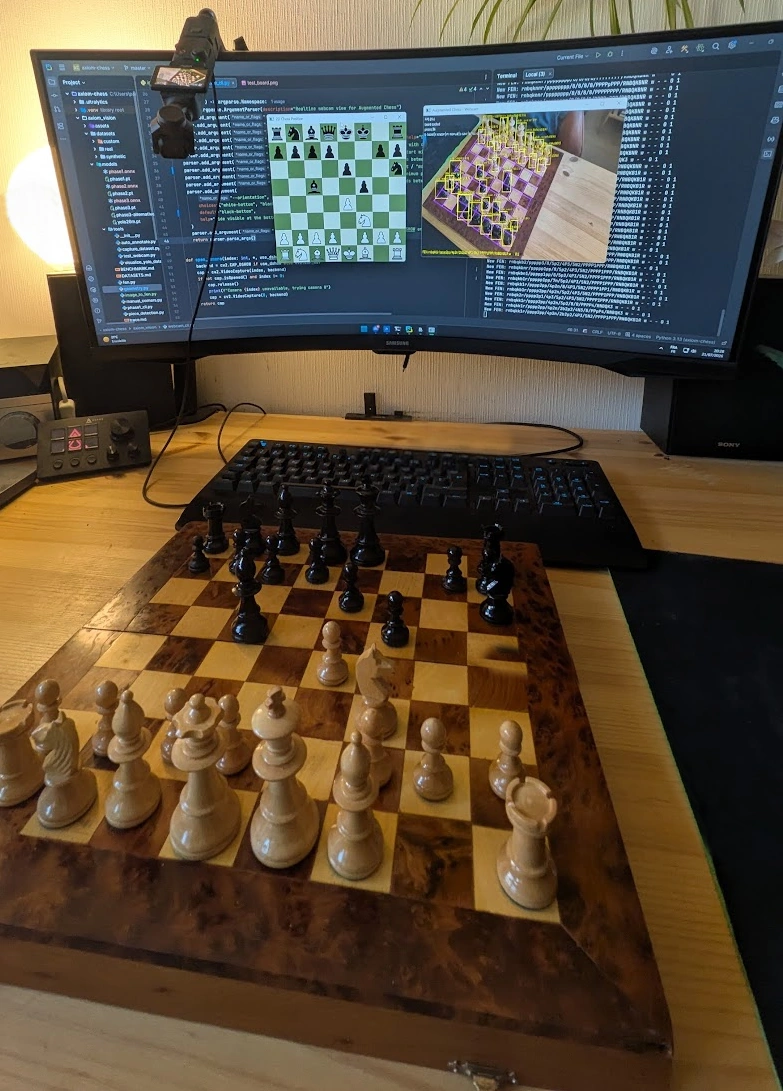
Axiom Chess is a comprehensive spatial computing and augmented reality chess ecosystem structured into three independent and complementary modules: Axiom Engine (a custom Minimax search engine with Alpha-Beta pruning evaluating positions with a trained SGD linear regressor across 7 normalized heuristics), Axiom Vision (a real-time computer vision pipeline utilizing YOLO Pose for 4-corner board homography and a 12-class YOLO model for piece localization), and Axiom Light (an augmented reality projection module projecting dynamic moves, legal paths, and analysis overlays directly onto physical chessboards in real time).
System Architecture & Modules
axiom-chess/
├── axiom_engine/              # AI Chess Engine & ML Evaluation
│   ├── alpha_beta.py          # Minimax search with Alpha-Beta pruning
│   ├── board_to_features.py   # Extraction of 7 normalized heuristic features
│   ├── model_evaluation.py    # Position evaluation using trained SGDRegressor
│   ├── model_training.py      # Batched parallel training pipeline
│   ├── axiom_model.pkl        # Serialized regression model weights
│   ├── main.py                # Interactive CLI to play against the engine
│   └── README.md              # Detailed engine documentation
│
├── axiom_vision/              # Computer Vision & Game Tracking
│   ├── core/                  # Board/piece detection, geometry, FEN extraction
│   ├── game/                  # Game state tracking (GameTracker) & engine bridges
│   ├── pipeline/              # Video stream, live webcam, static image pipelines
│   ├── tools/                 # Capture, auto-annotation & PTZ control tools
│   ├── models/                # AI model weights (phase_a2.pt, phase3.pt, yolo26m.pt)
│   ├── assets/                # 2D graphics for board overlay
│   └── main.py                # Vision entry point
│
├── axiom_light/               # Augmented Reality & Physical Projection
│   ├── calibrator.py          # Camera-projector geometric calibration & homography
│   ├── main.py                # Real-time board tracking & dynamic projection
│   ├── calibration_geometry.npy # Saved calibration homography matrix
│   └── nudge_offsets.npy      # Saved fine-tune millimeter offsets
│
├── main.py                    # Unified main entry point
└── requirements.txt # Consolidated project dependenciesCore Module 1: Axiom Engine
Unlike traditional chess engines that rely on static, manually tuned piece-square tables, Axiom Engine pairs classic Minimax search and Alpha-Beta pruning with a machine-learning heuristic evaluator. Positions are converted into 7 normalized feature vectors before inference via an SGDRegressor.
7 Extracted Heuristic Features
Material balance, King safety, Center control, Pressure/Attacks, Piece development, Global square control, and Dynamic mobility.
Parallel Training Pipeline
Trained on massive game databases using batched mini-batch stochastic gradient descent to align continuous evaluation scores.
Core Module 2: Axiom Vision
Axiom Vision turns standard video streams or live PTZ webcams into digital game state records (FEN). The vision pipeline operates in two synchronized deep-learning stages:
Board Detection & Warp
YOLO Pose model detects the 4 physical board corners, enabling a perspective warp into a normalized 8x8 square reference plane.
Piece Classification & Anchor Projection
A 12-class YOLO model detects pieces and projects their bottom-center contact points onto the corresponding grid cell, overcoming perspective occlusions.
Temporal Move Stability
A temporal window filters out player hand movements and transient occlusions before committing a legal move to the game tree.
Core Module 3: Axiom Light
Axiom Light bridges the digital and physical worlds by projecting contextual guidance onto the physical board. It features automated homography calibration between the projector lens and the tracking camera, with sub-millimeter keyboard nudge adjustments (N key). The projected light highlights opponent moves, hints optimal engine moves, and projects danger zones directly onto the pieces.
Key Engineering Highlights
Real-Time Computer Vision (Axiom Vision)
Instant 4-corner board detection using YOLO Pose (phase_a2.pt) and 12-class piece recognition (phase3.pt) with bottom-center anchor projection.
Dynamic AR Projection (Axiom Light)
Camera-projector homography mapping perspective-corrected game moves, threats, and engine evaluations directly onto physical wooden boards.
Hybrid Engine Evaluation (Axiom Engine)
Alpha-Beta Minimax search evaluating positions with an SGD linear regressor trained over 7 normalized heuristics instead of hardcoded piece-square tables.
Temporal Move Validation & PGN Export
Temporal stability filtering confirms physical human moves, verifies move legality through python-chess, and exports live matches to standard PGN files.
Execution & Quickstart Commands
python main.pypython main.py -m visionpython main.py -m engine --depth 3 --color whitepython main.py -m light --camera 1